Plan-Conditioned Imitation for Robust Object Retrieval
under Self-Occlusion in Dense Clutter
1 Rutgers University2 Indian Institute of Technology Bombay.
Teacher Rollouts for Adaptive Closed-loop Execution
A robot’s arm blocks its own view. TRACE uses one initial plan, memory,
and partial feedback to retrieve a target object from dense clutter.
Overview
Supplementary video · 2:59Target retrieval in dense clutter under self-occlusion.
INSIDE TRACE
Training & inference
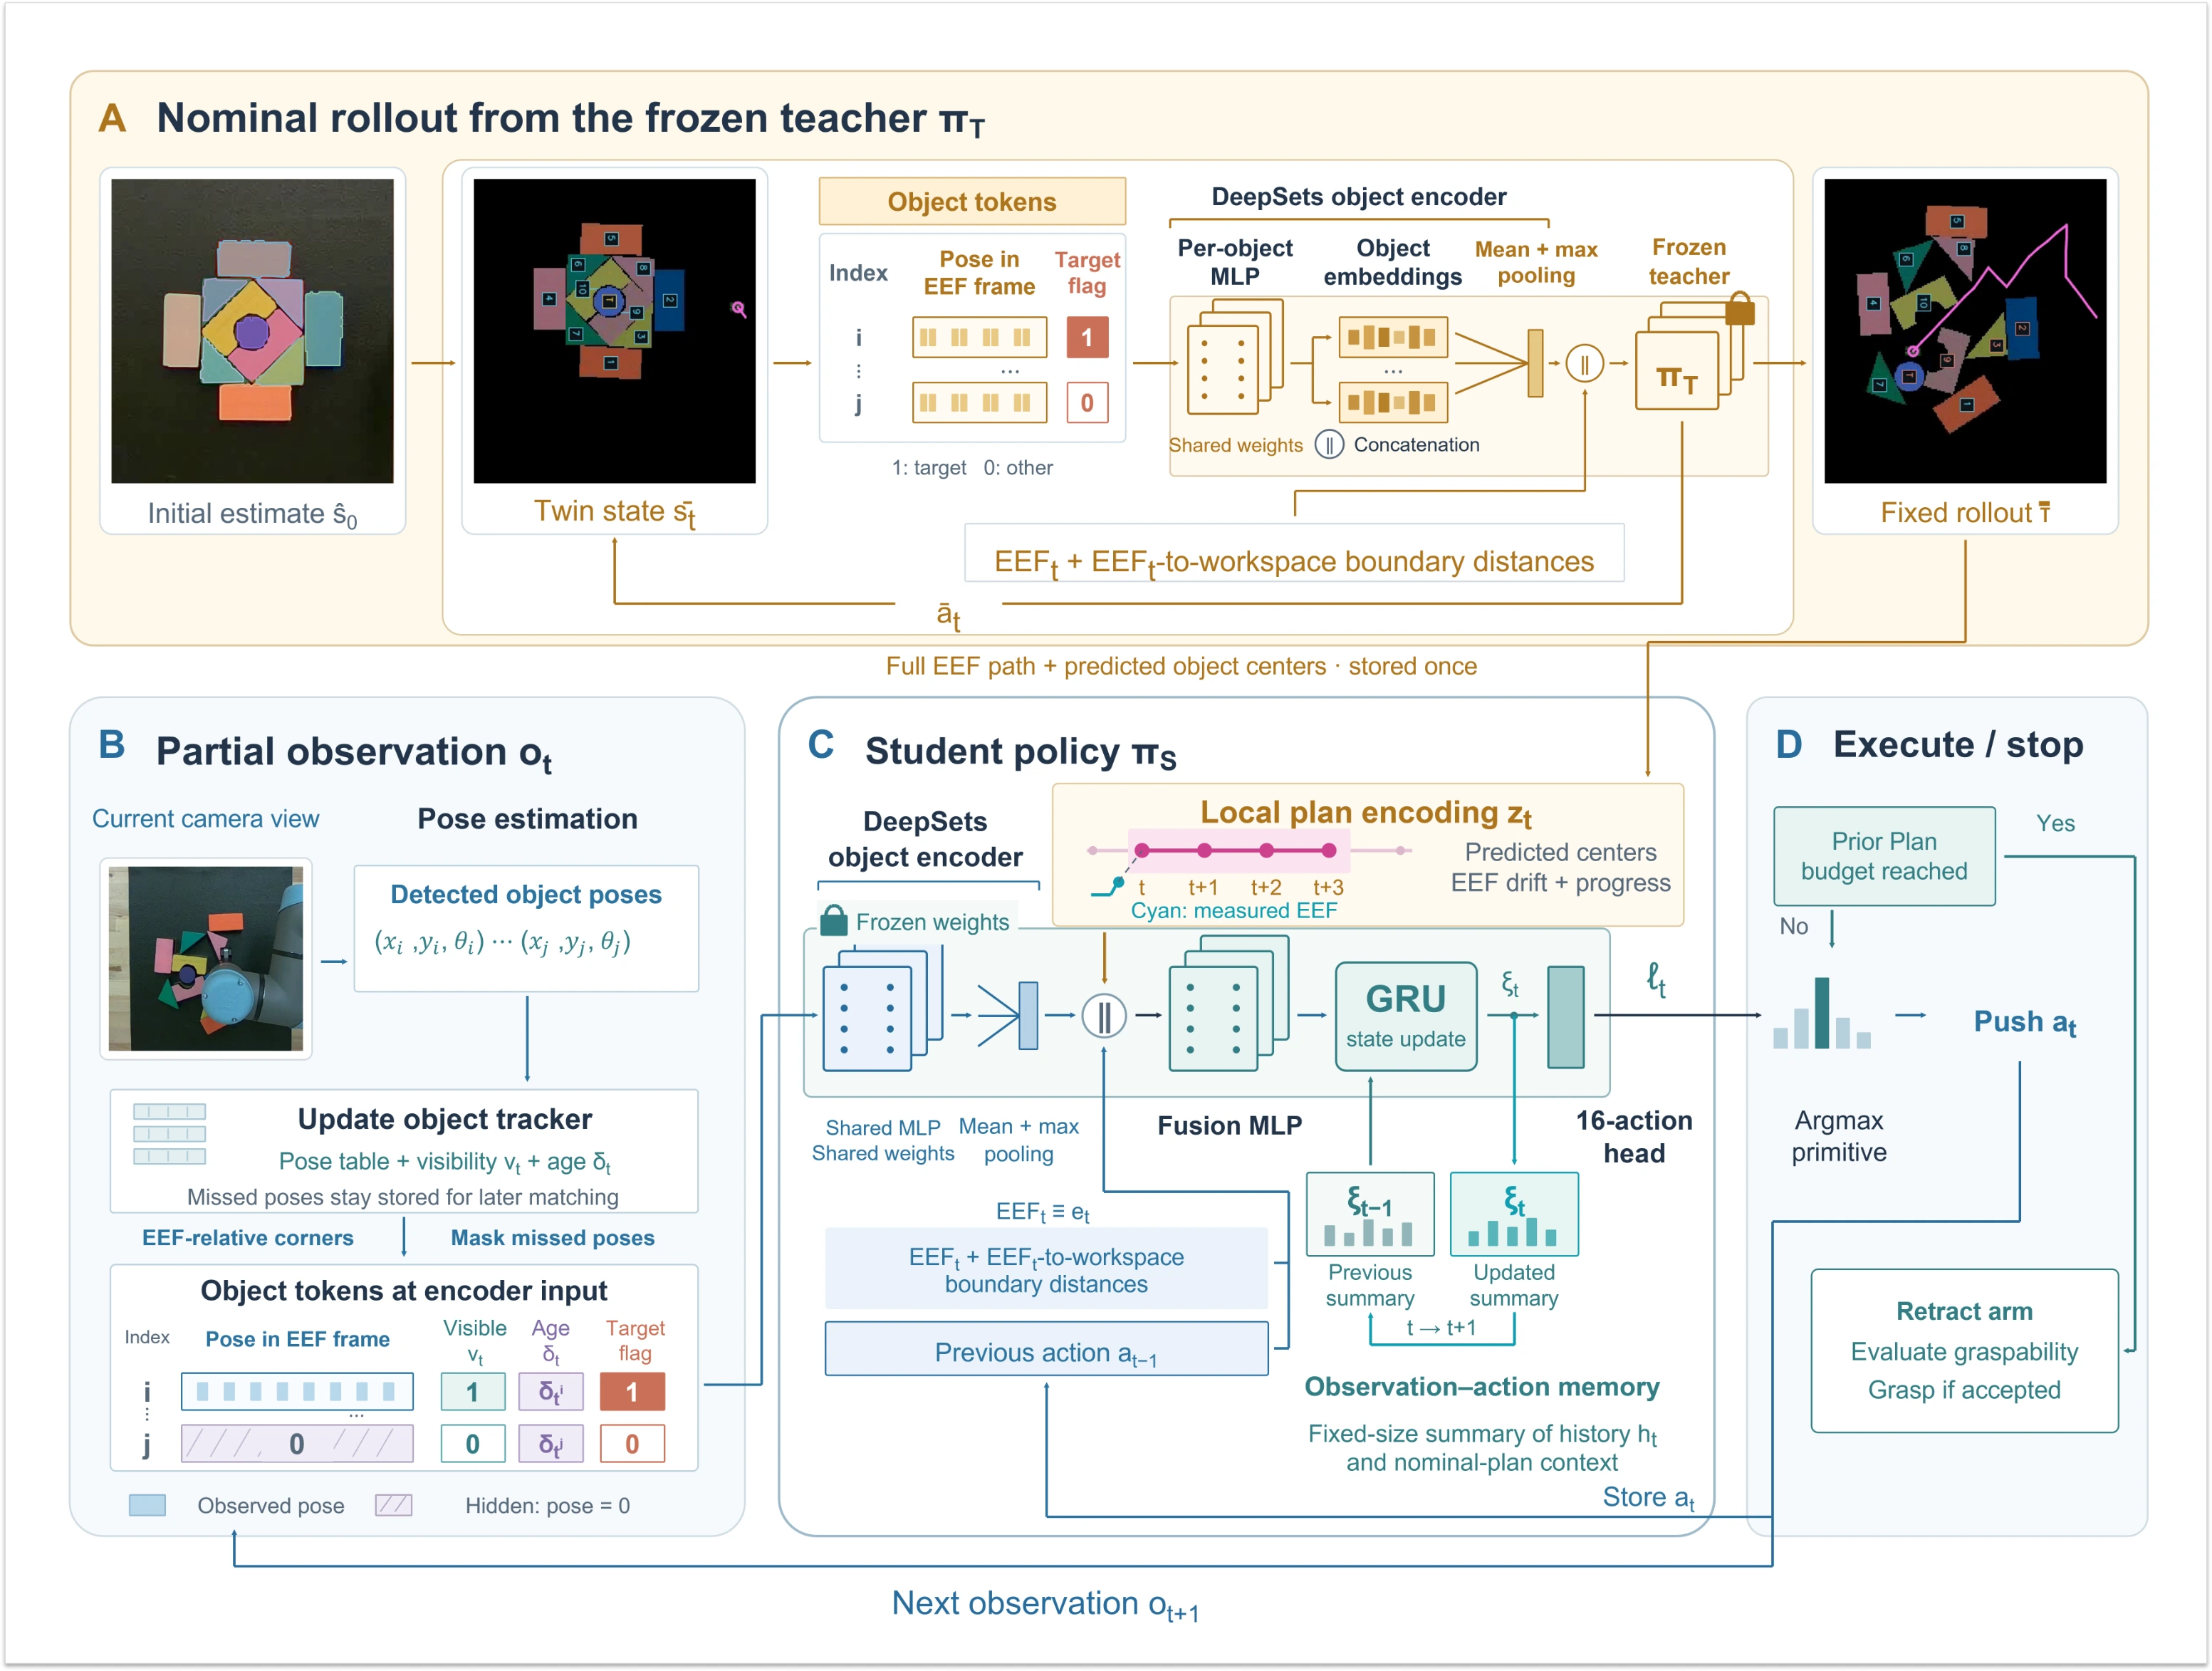 View full resolution
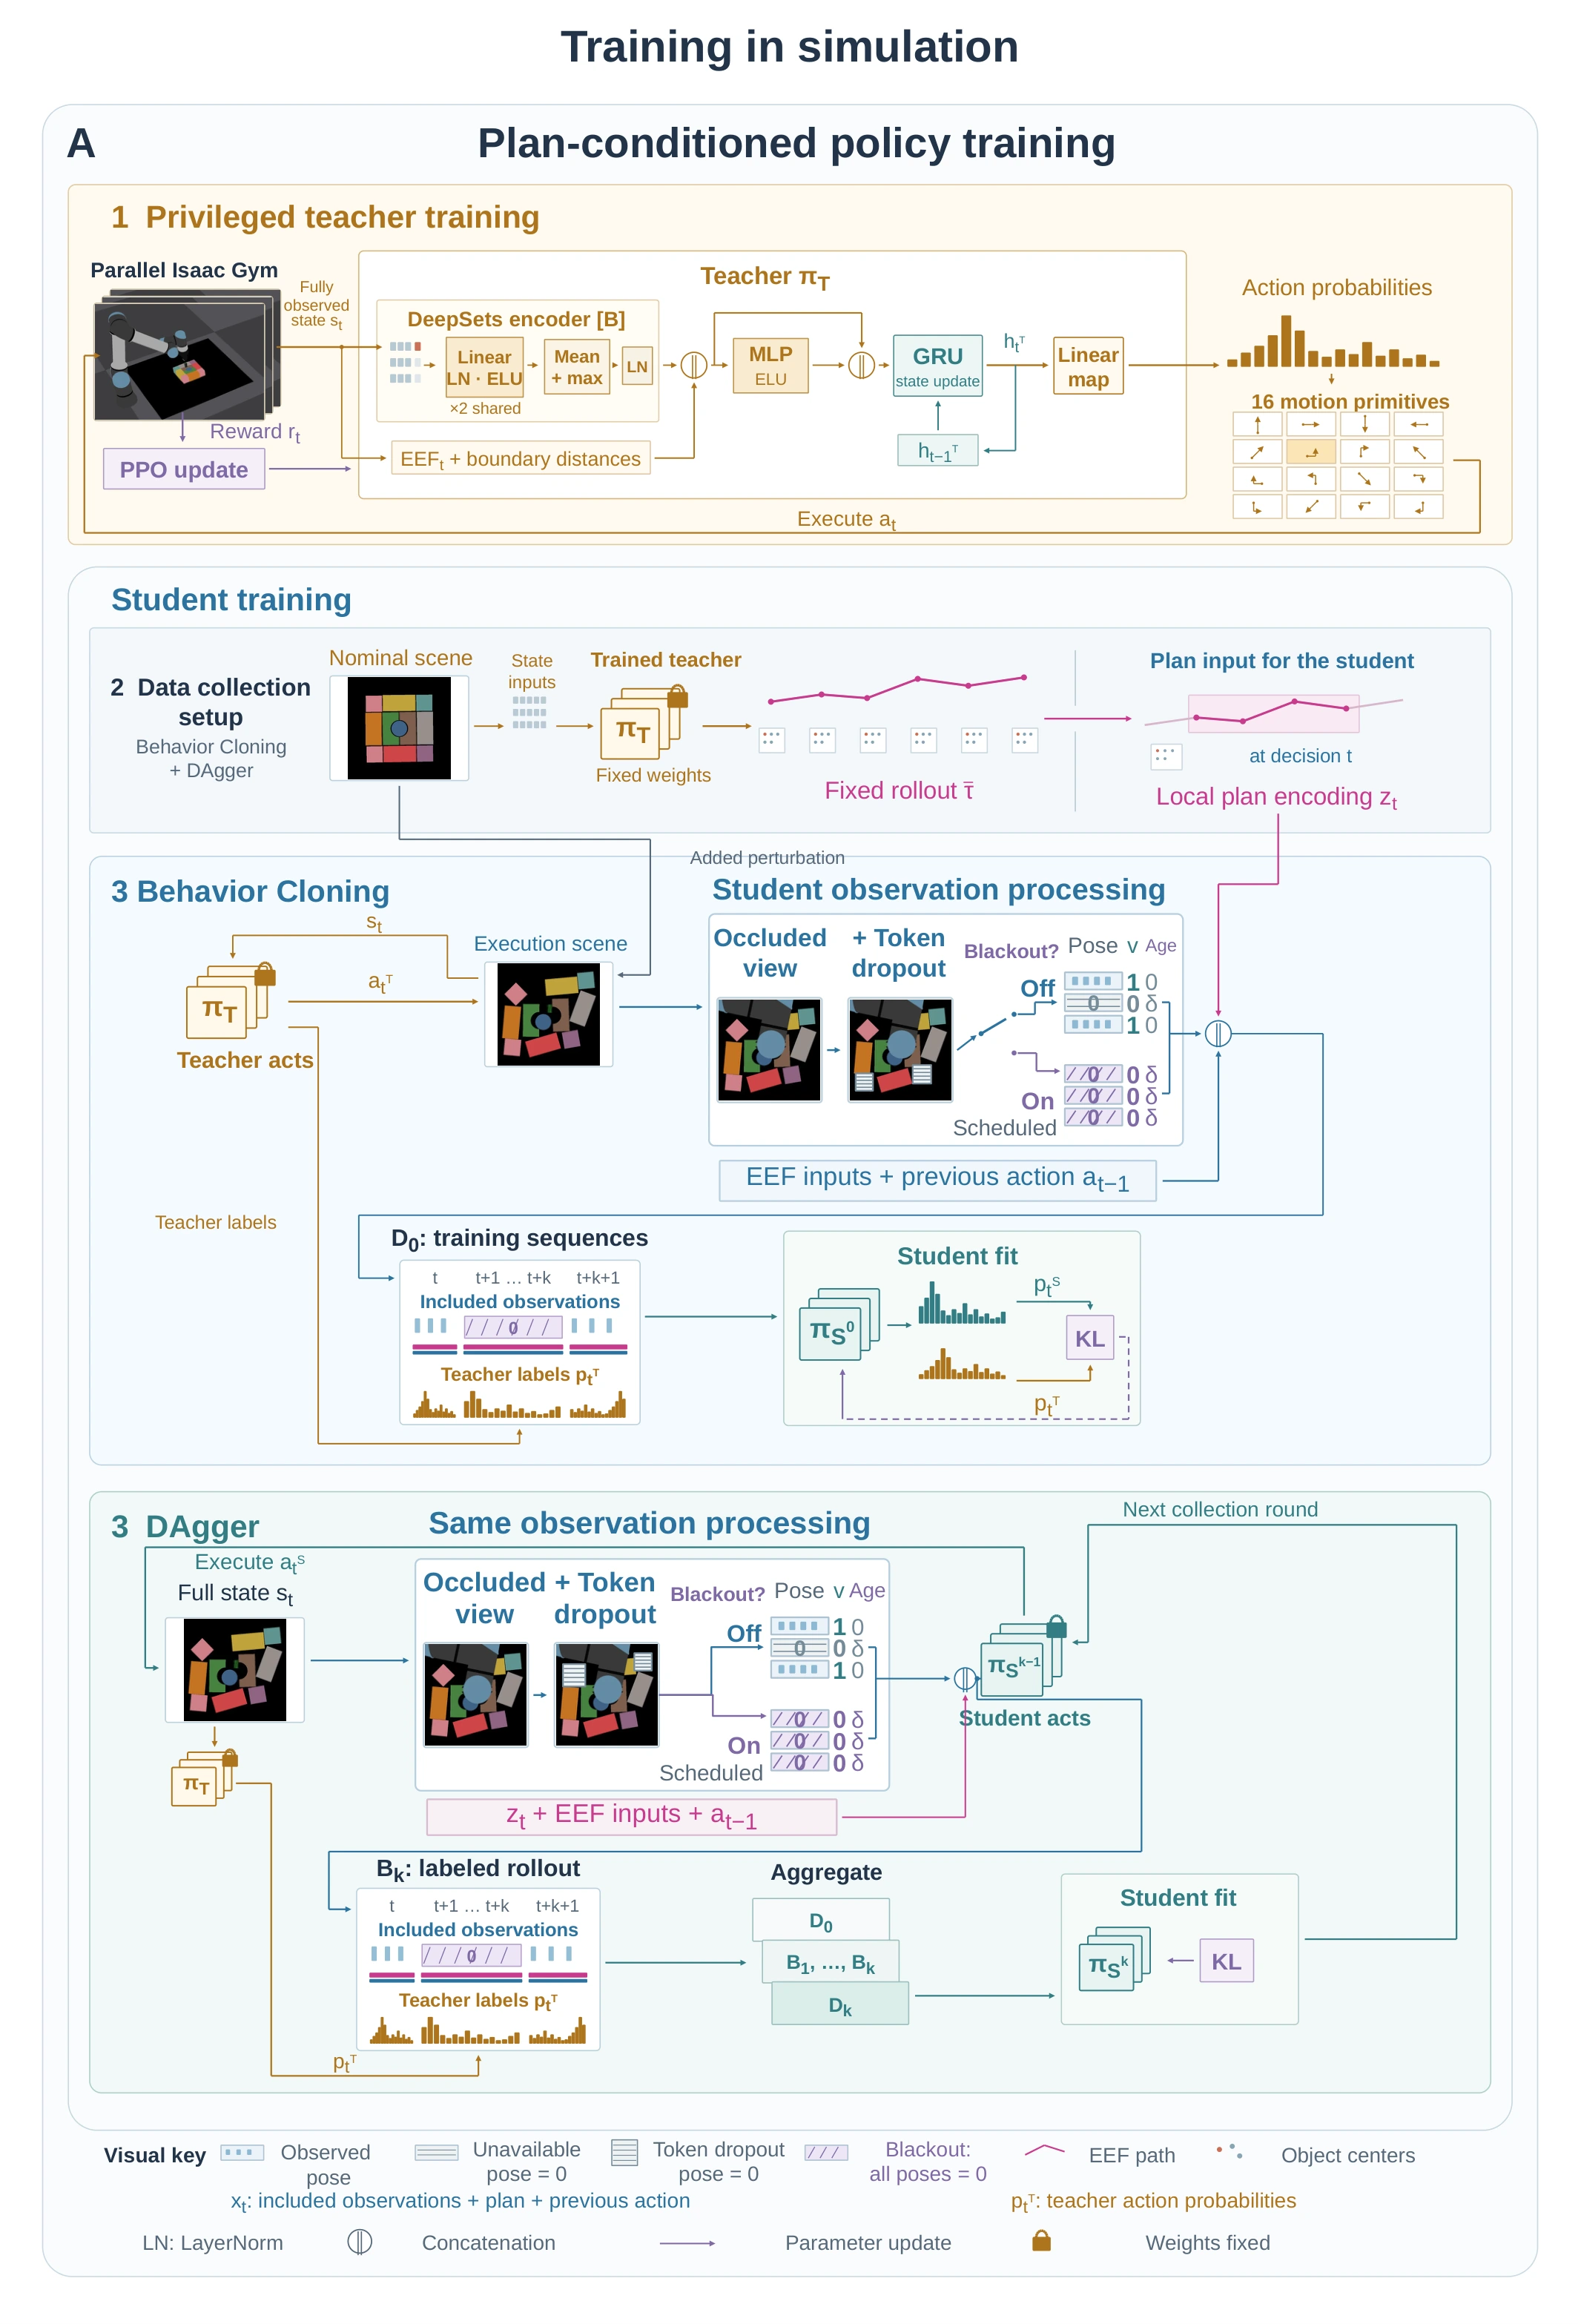 View full resolution
On the real robot, we estimate object poses from instance masks produced by Mask R-CNN (He et al., ICCV 2017).
ON THE REAL ROBOT
Demonstrations
Choose a method and scene.
Outcome: Success
Scene 01
90.0% success67.3 s total2.9× faster than Online Teacher, with no sensing retractions during pushing.
Outcome: Success
Scene 01
95.0% success192.7 s totalHighest success, but 2.9× TRACE’s total time and repeated sensing retractions.
Outcome: Failure
47.5% success49.5 s totalFaster than TRACE, but 42.5 percentage points less success without execution feedback.
Outcome: Failure · Timeout
Scene 01
85.0% success141.1 s total5 percentage points less success and 2.1× TRACE’s total time, with complete-scene sensing.
Outcome: Failure · Out of workspace (OOW)
Scene 01
77.5% success44.4 s totalFastest, but 17.5% out-of-workspace (OOW) failures versus 0% for TRACE.
Selected videos; statistics cover the full hardware benchmark: 20 scenes × 2 trials per method. Total time includes initialization/planning, execution, and grasp/lift.
Citation
@misc{boyalakuntla2026trace,
  title = {Plan-Conditioned Imitation for Robust Object Retrieval under Self-Occlusion in Dense Clutter},
  author = {Boyalakuntla, Kowndinya and Pawar, Ajinkya and Boularias, Abdeslam and Yu, Jingjin},
  year = {2026},
  url = {https://trace-retrieval.github.io/}
}